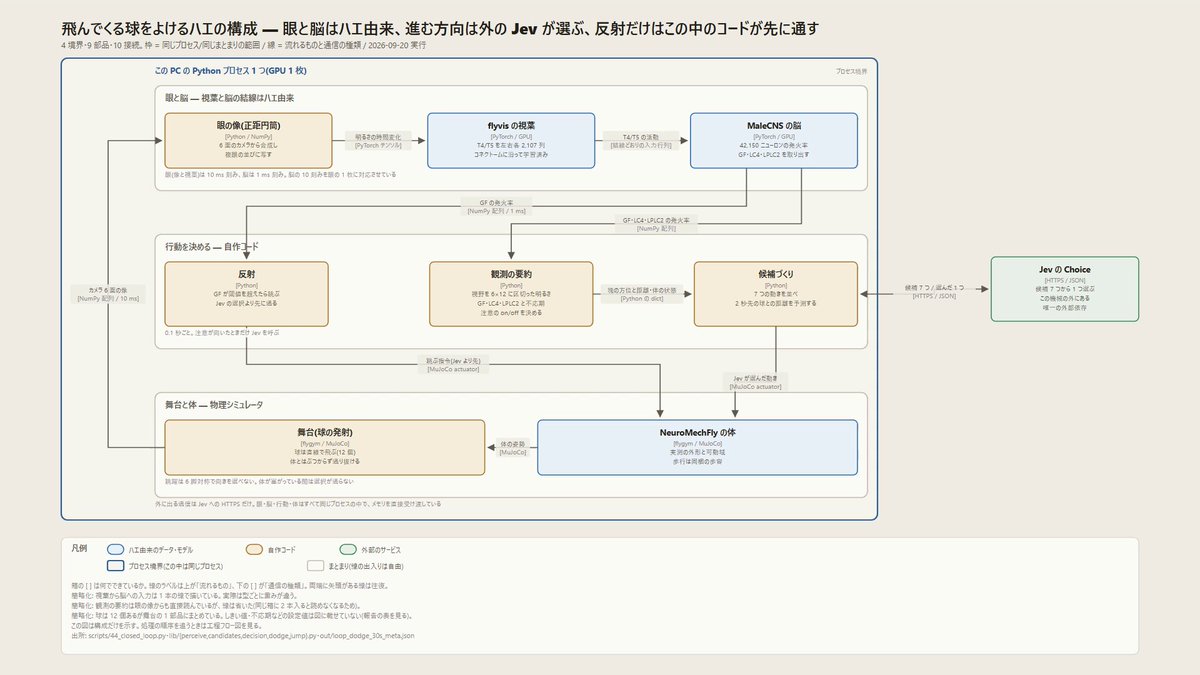
Choosing one of seven steering actions from precomputed ball trajectories while separate modules handle vision and reflexes
 bestjev home
Jev Hardware Demos
See 38 real Jev demos showing how it handles robot control, visual guidance, and device decisions, with videos and the original posts.
Last updated
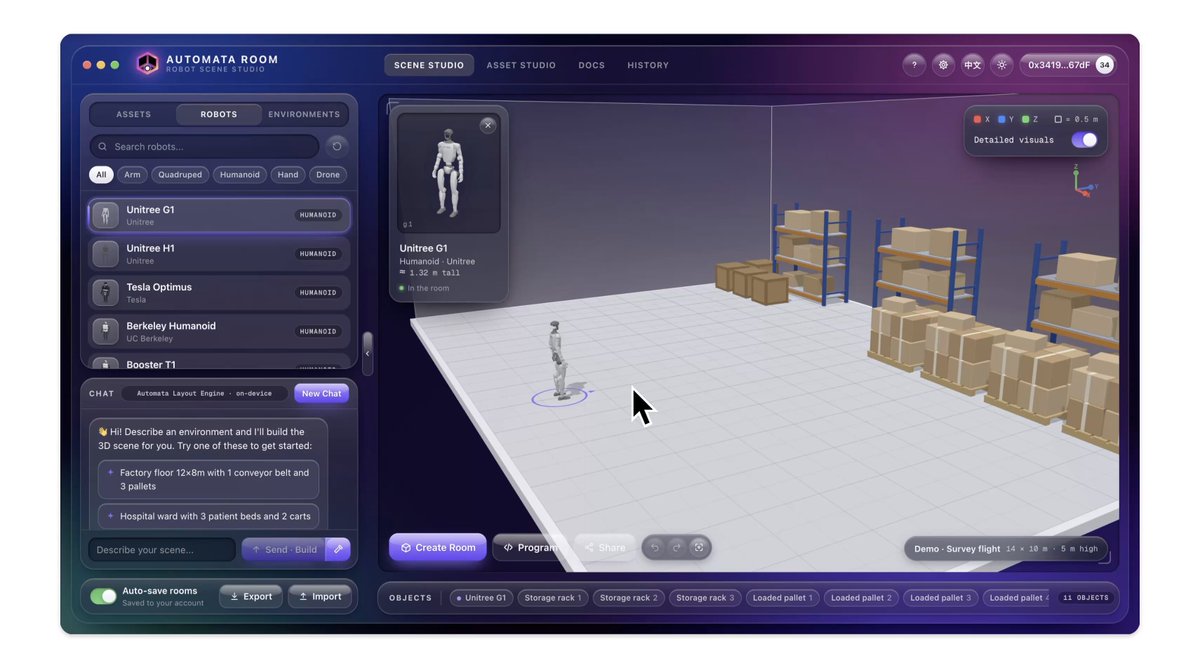
Planning a Unitree G1 route to carry four crates one at a time and return to the entrance with fewer, shorter trips
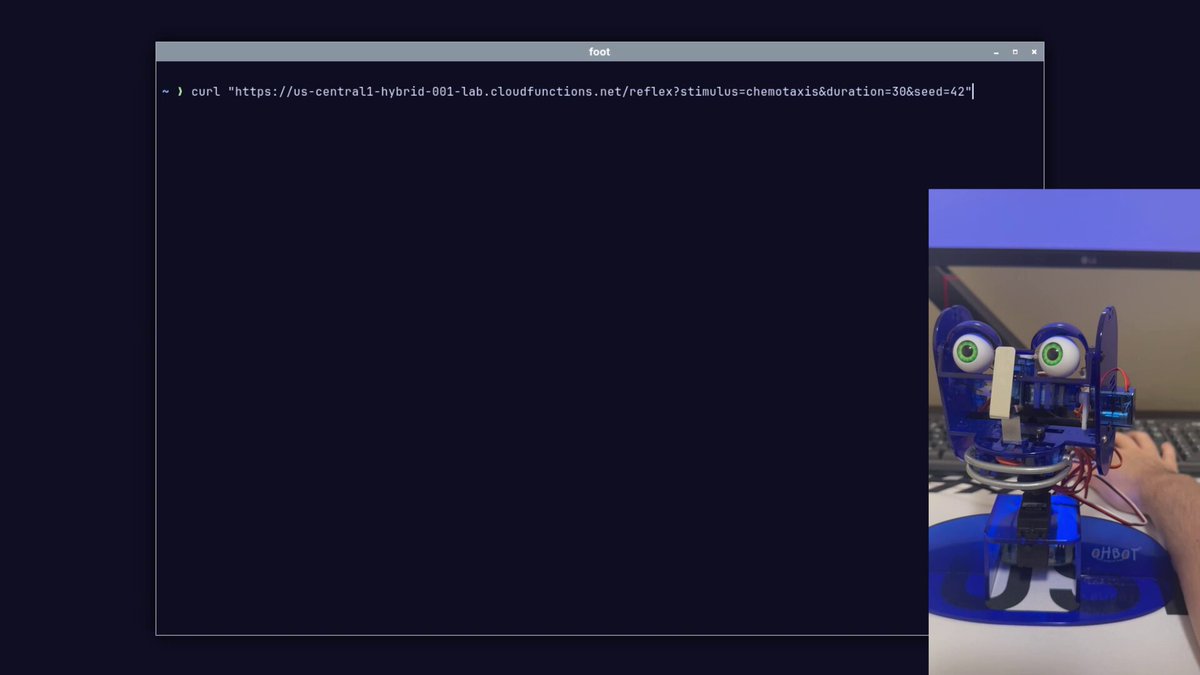
Translating simulated neural activity into rapid decisions and physical movement for a bio-inspired robot
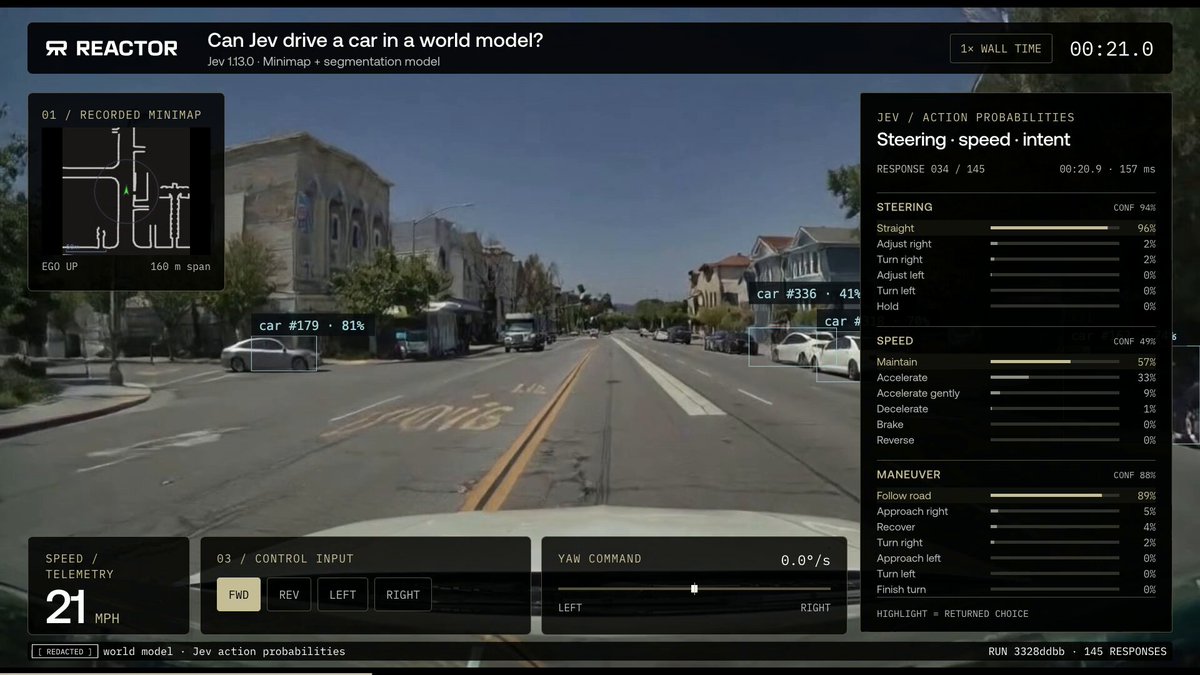
Combining a self-driving world model and local segmentation to provide text state for autonomous steering decisions
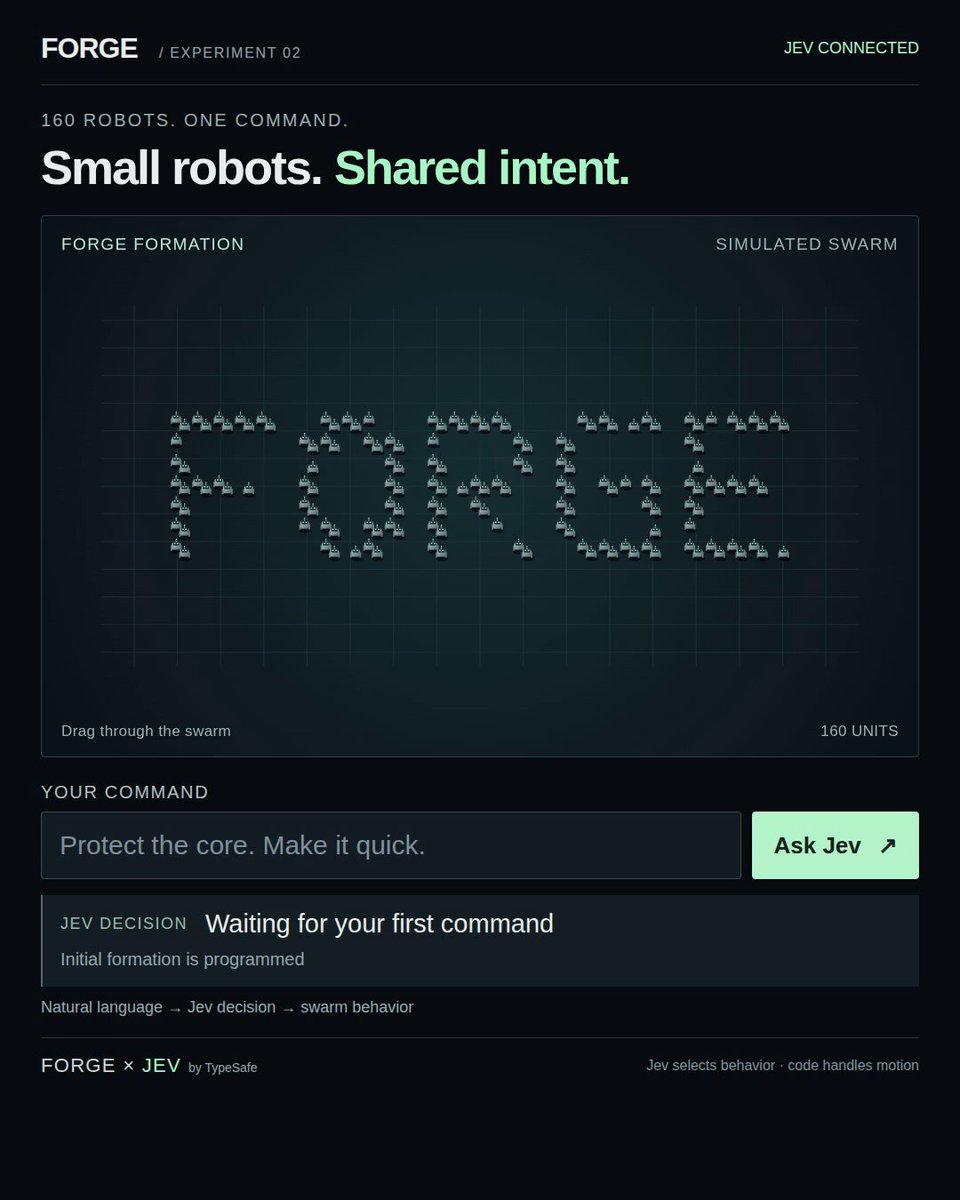
Coordinating the behavior of 160 simulated robots after extending a smaller game-control experiment
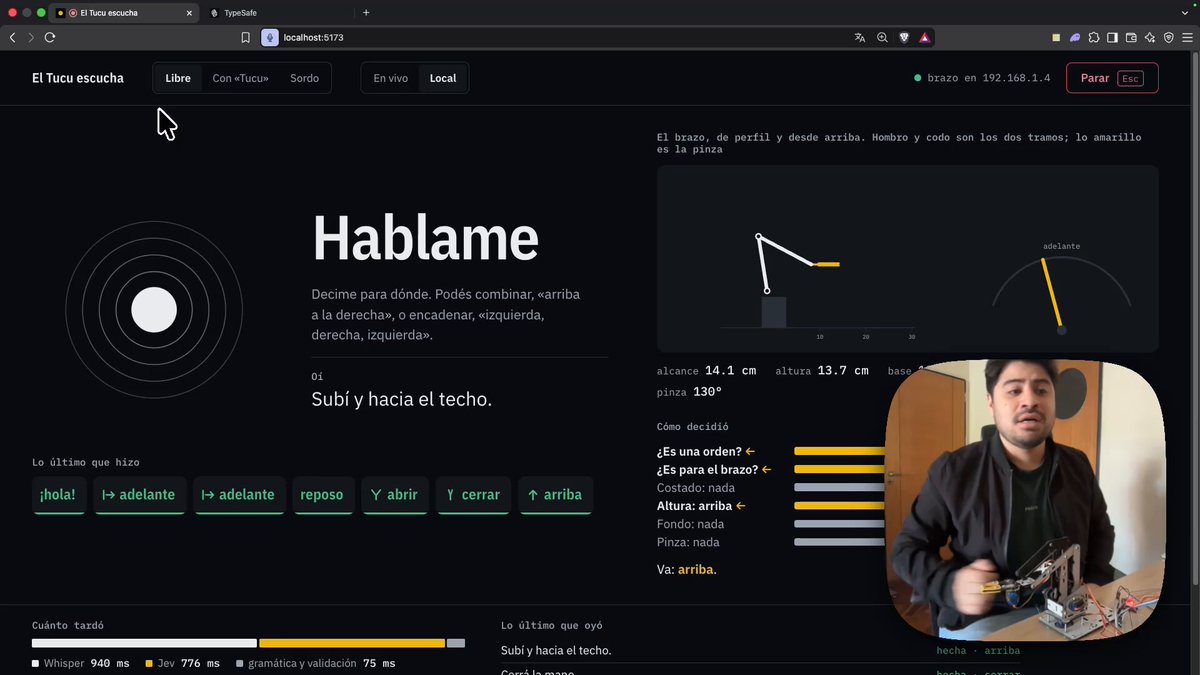
Translating natural-language commands such as open, reach, or stretch into robot-arm actions
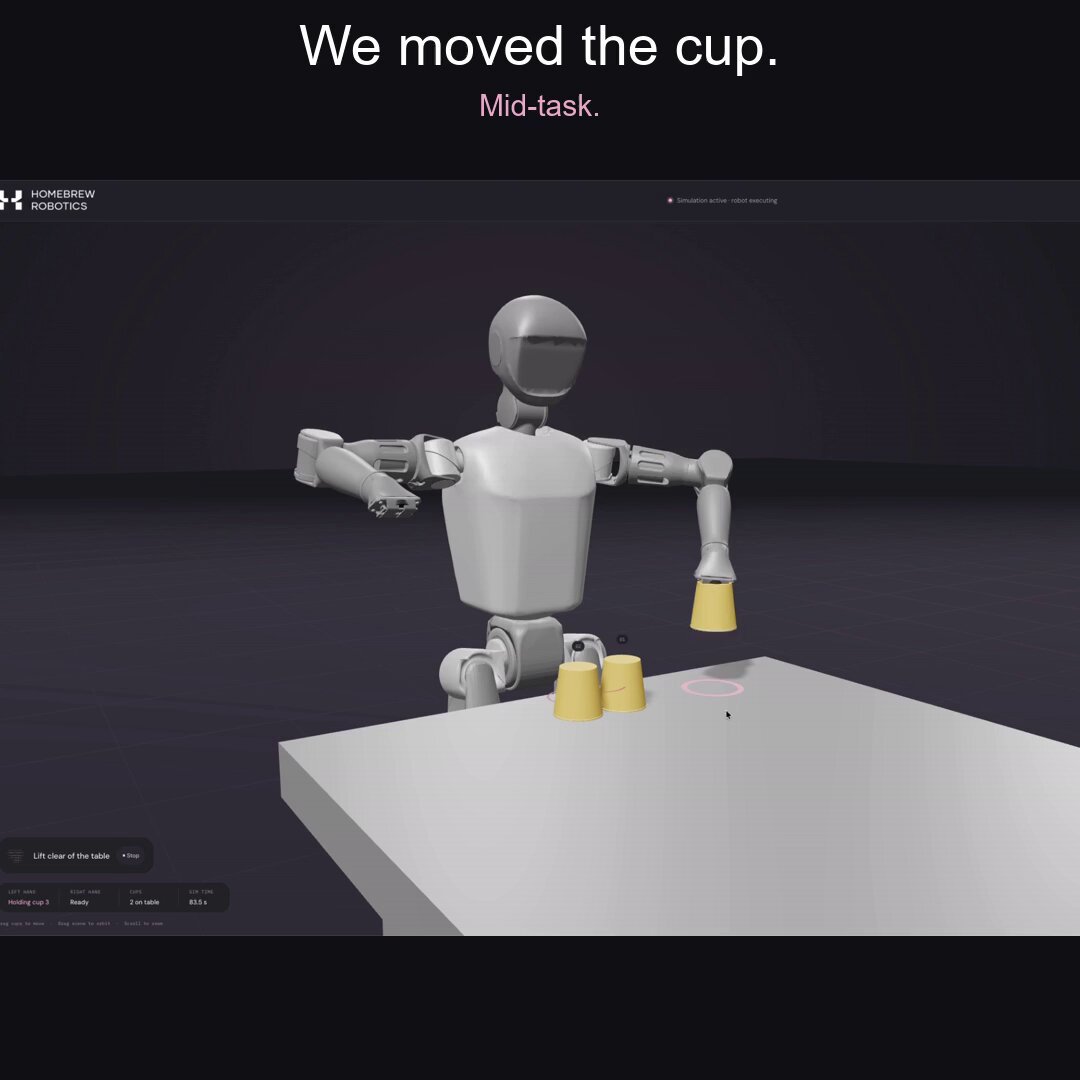
Choosing among six recovery options after a cup is moved, then replanning a humanoid's stacking sequence with 65% confidence
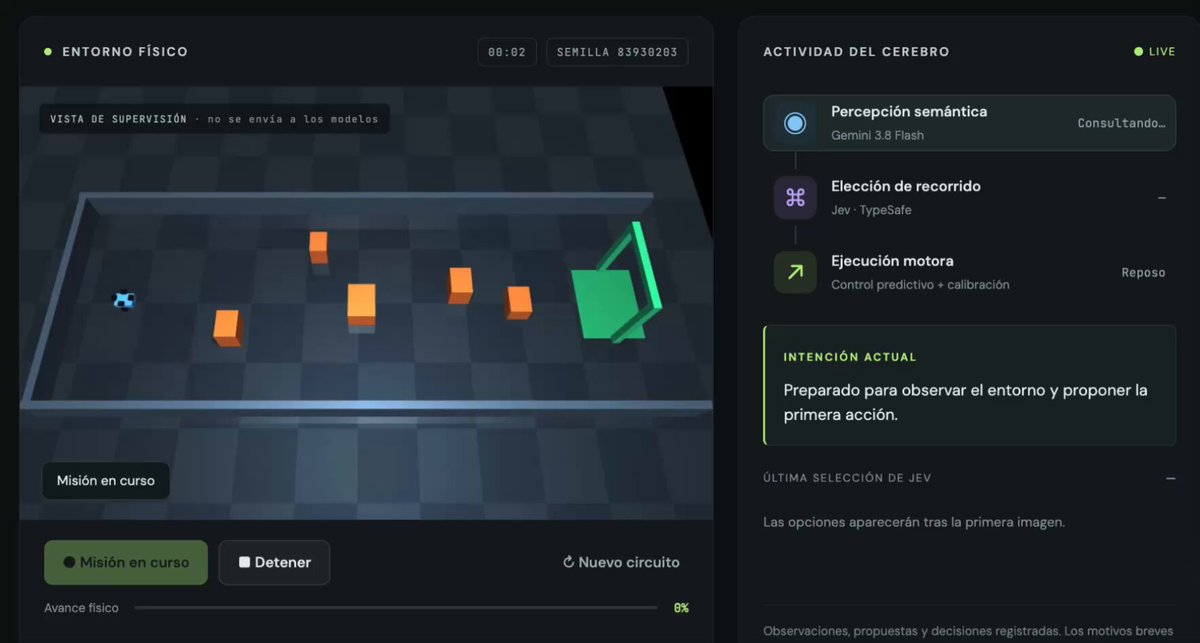
Providing rapid action decisions for an autonomous robot prototype that previously lacked a responsive control layer
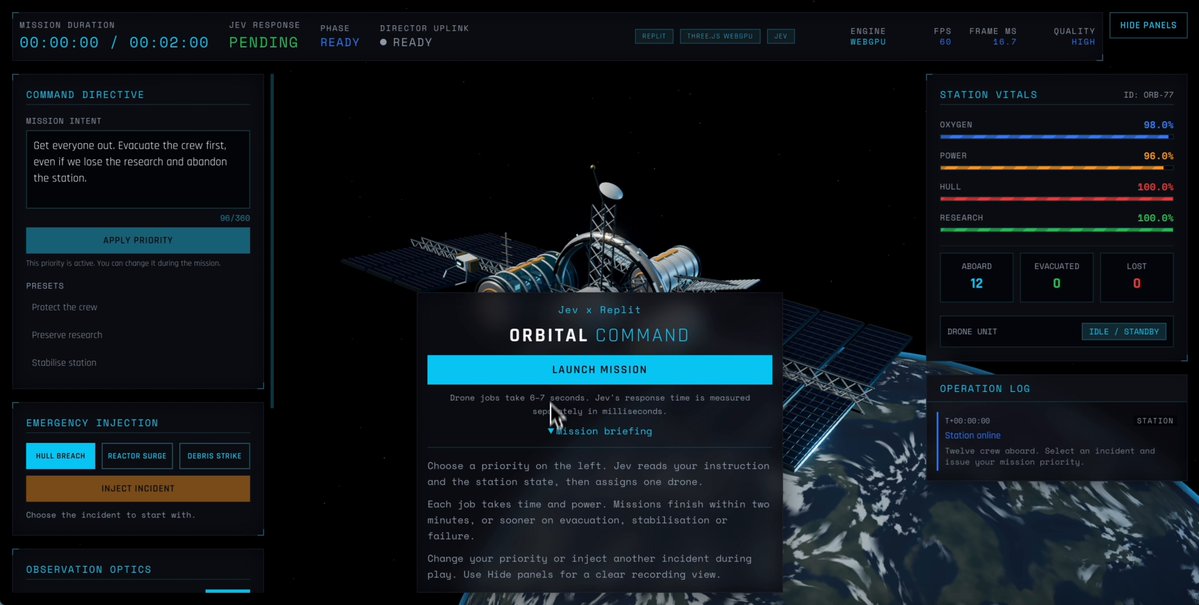
Assessing rescue-station risk and urgency to choose a drone's next action, with 12 crew rescued and a reported 208 ms average response
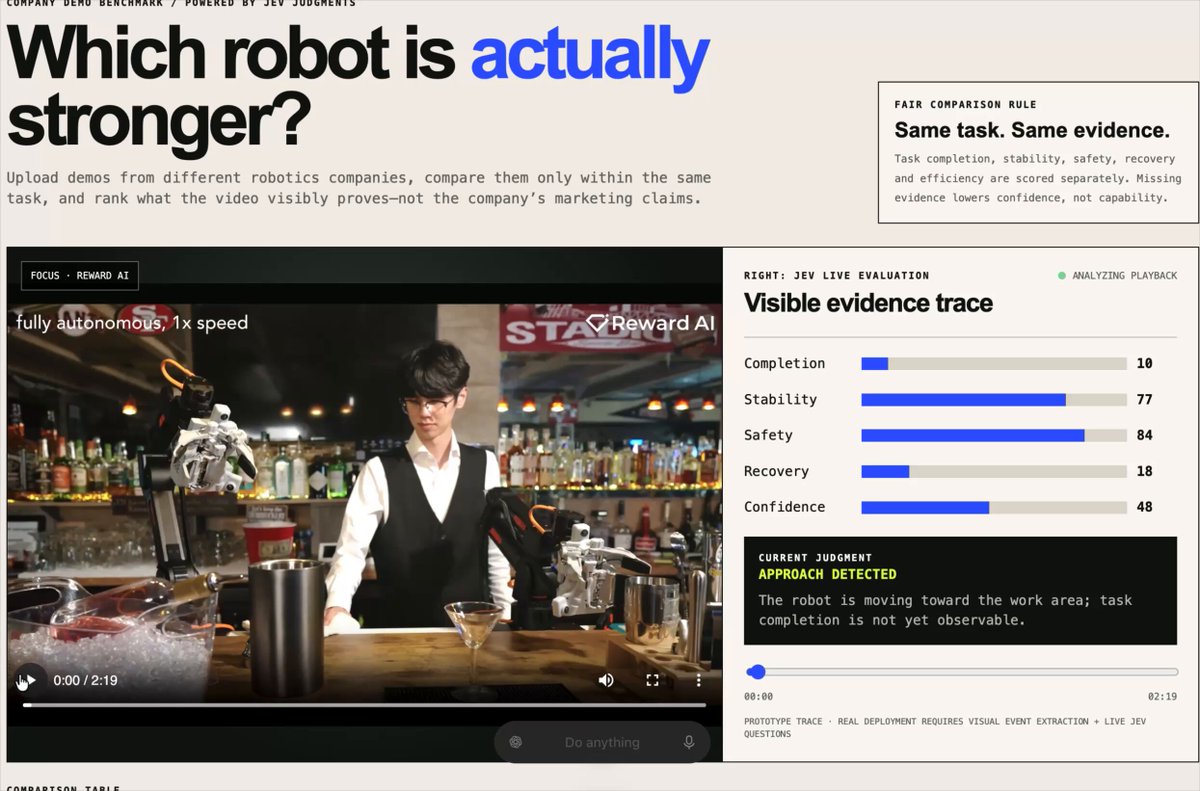
Tracking completion, stability, safety, recovery and uncertainty over time in robotics demo videos
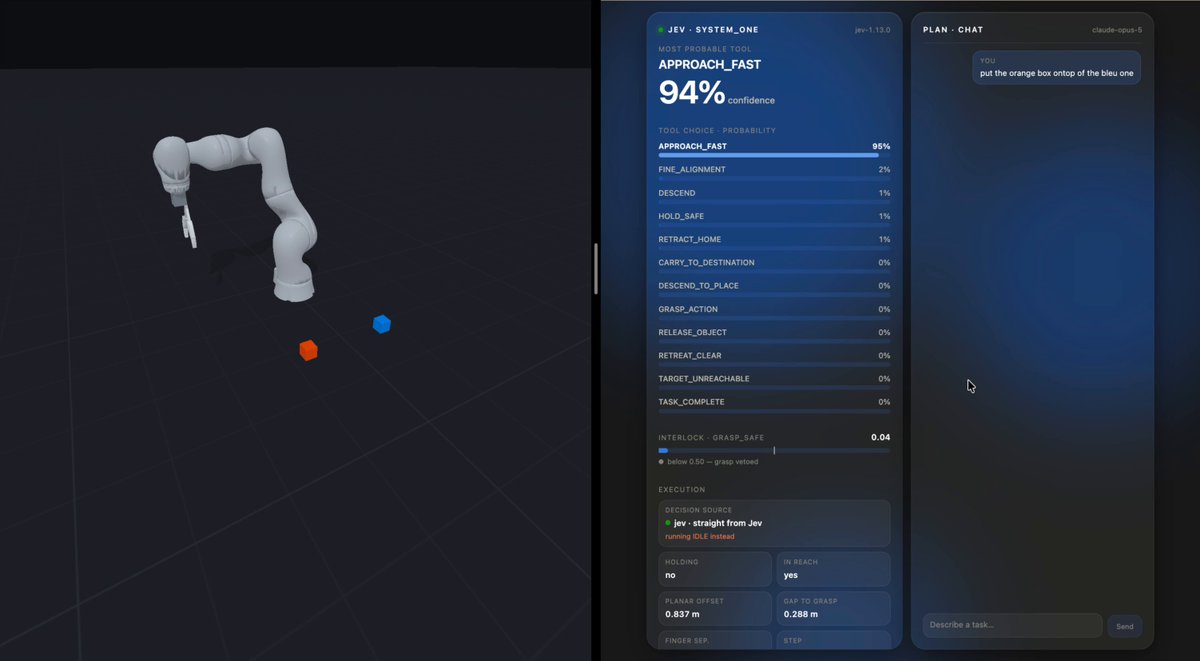
Letting Claude plan cube stacking while Jev adapts PyBullet robot actions in under 100 ms
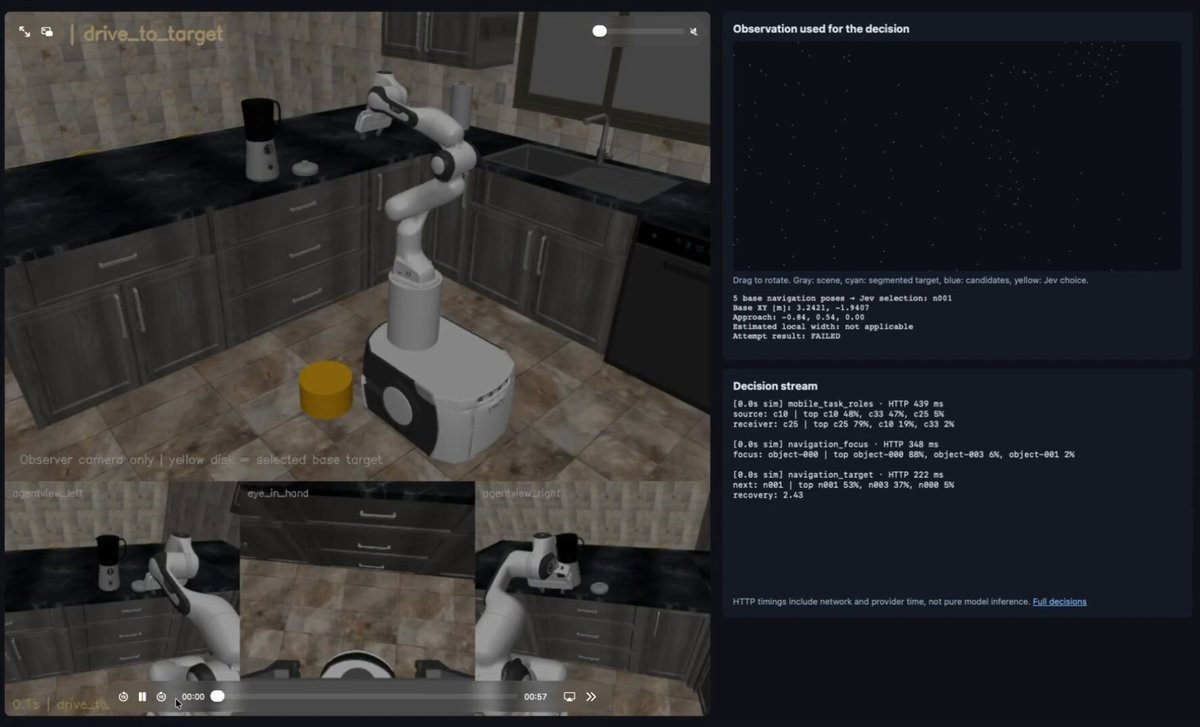
Combining SAM 3 depth observations with sampled movement, grasp and placement poses, then ranking actions for a simulated mobile robot
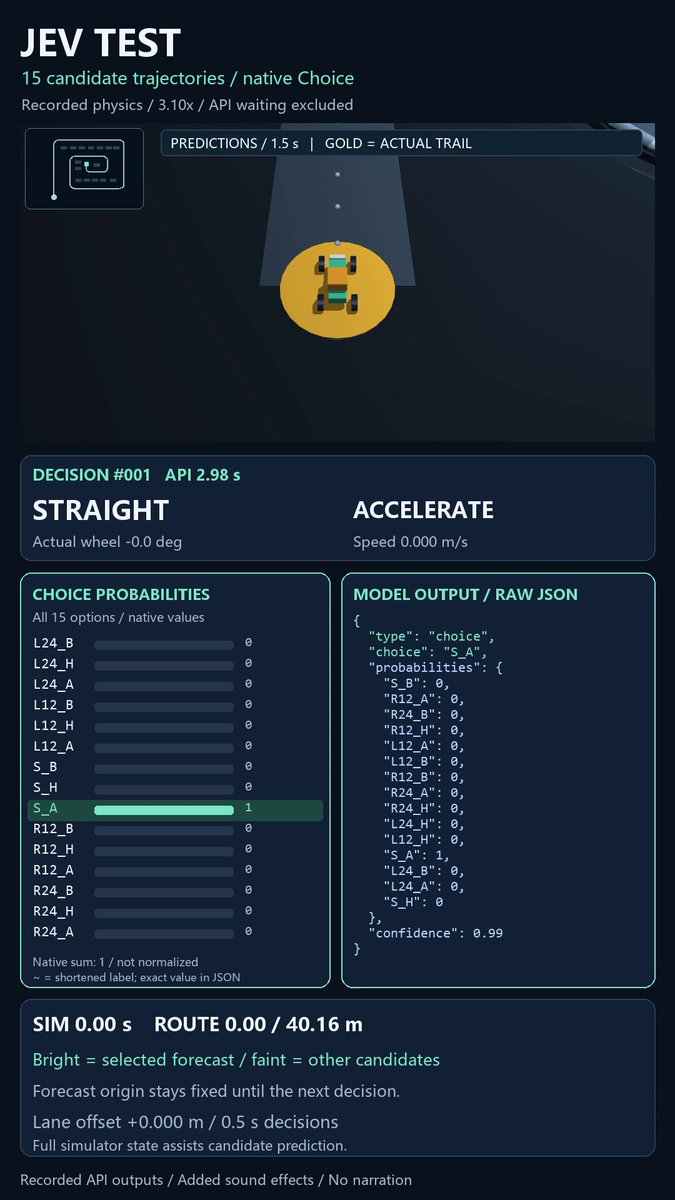
Choosing among 15 simulated driving trajectories every 0.5 seconds, finishing 261 calls with zero reported collisions for $0.18
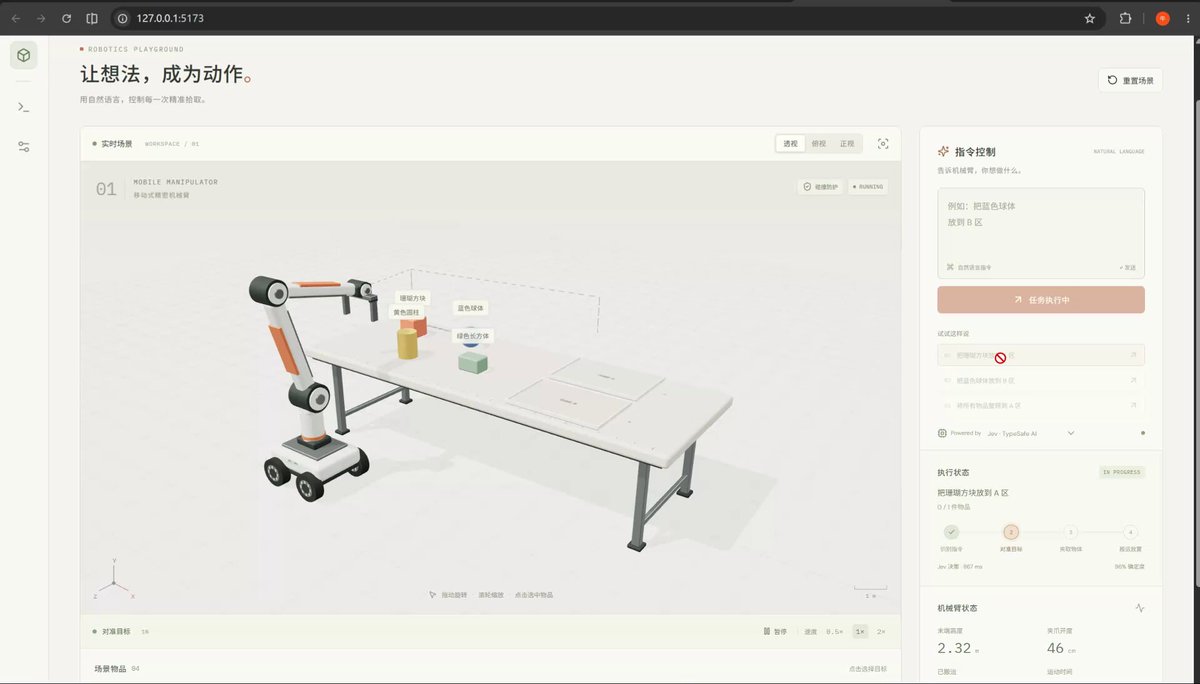
Executing text-commanded tasks with a robotic arm using kinematics and modeling generated by GPT 6 Astra
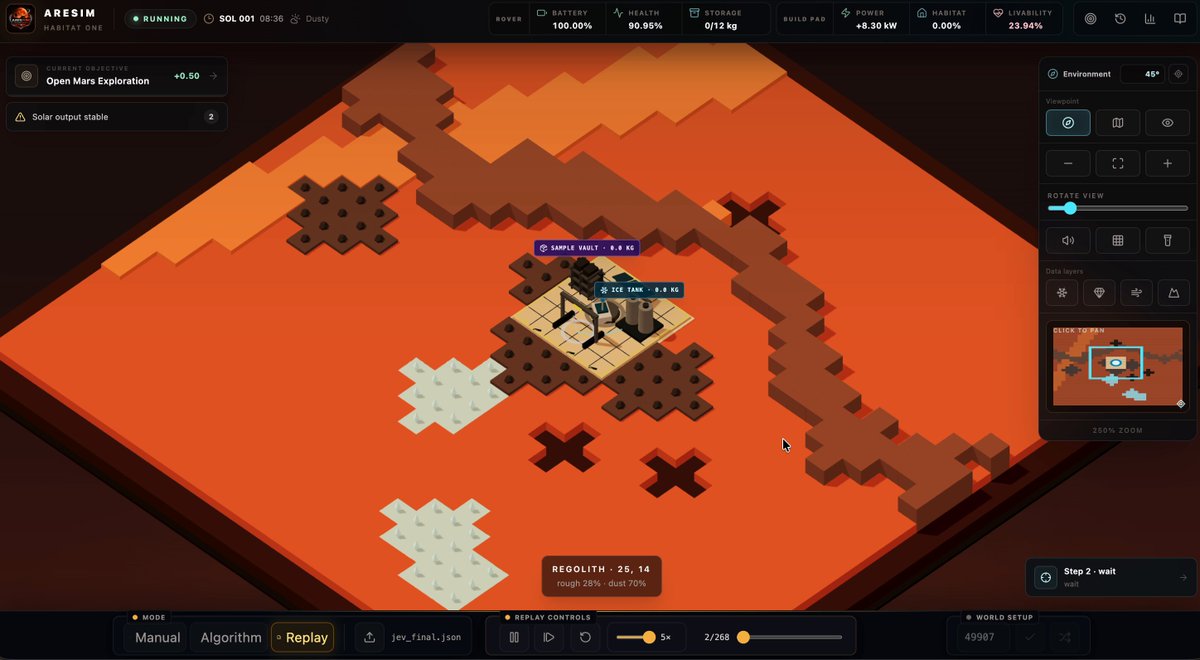
Steering an AresSim rover for 50 steps and reportedly matching an earlier Masked PPO policy
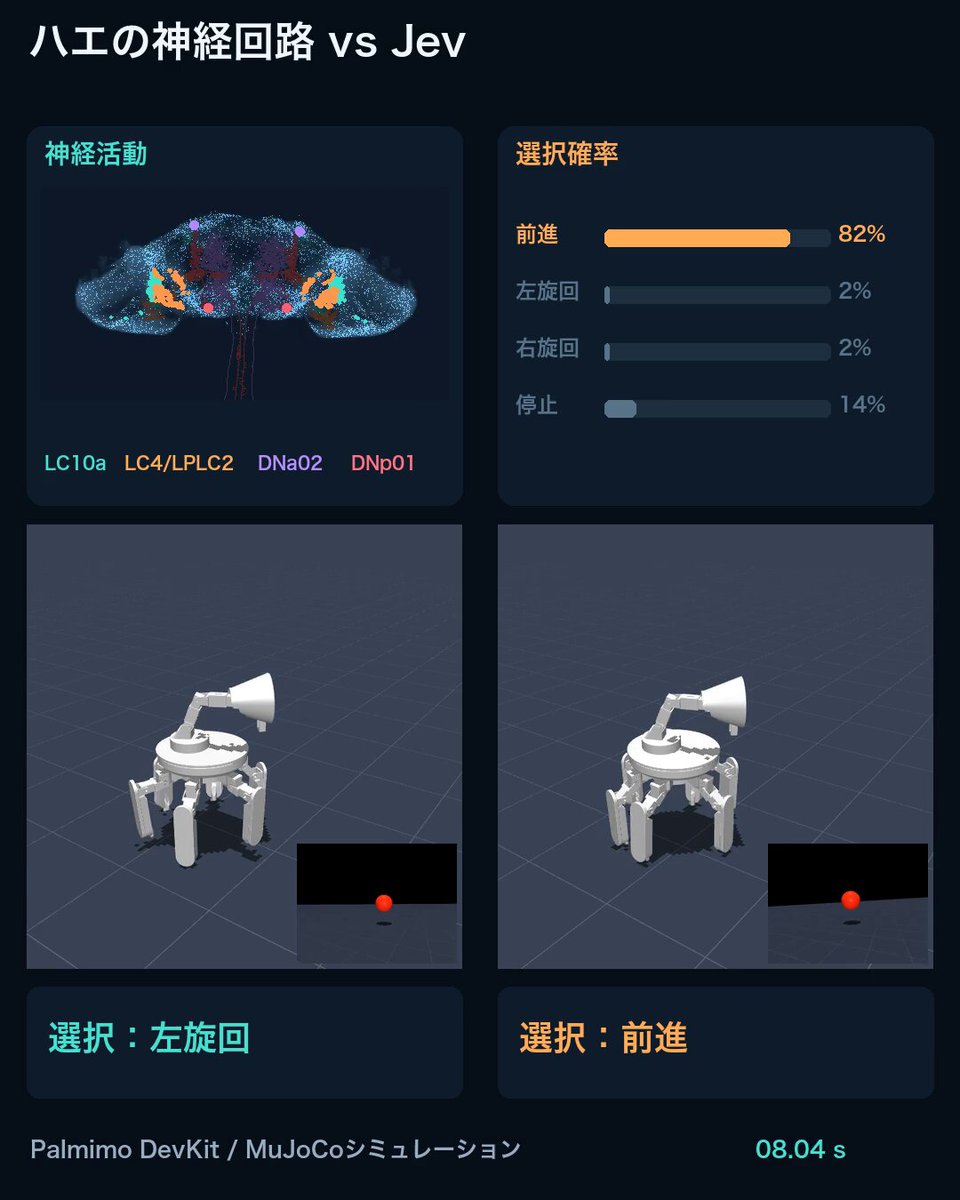
Comparing Jev with a roughly 160,000-neuron fly model on tracking a red ball and stopping when close in MuJoCo, with Jev reportedly winning
Planning a robot's route after every movement by replacing Claude in an older RobotClaw experiment
Keeping a flower alive with a robot that extinguishes fire, warms frost and admits a bee
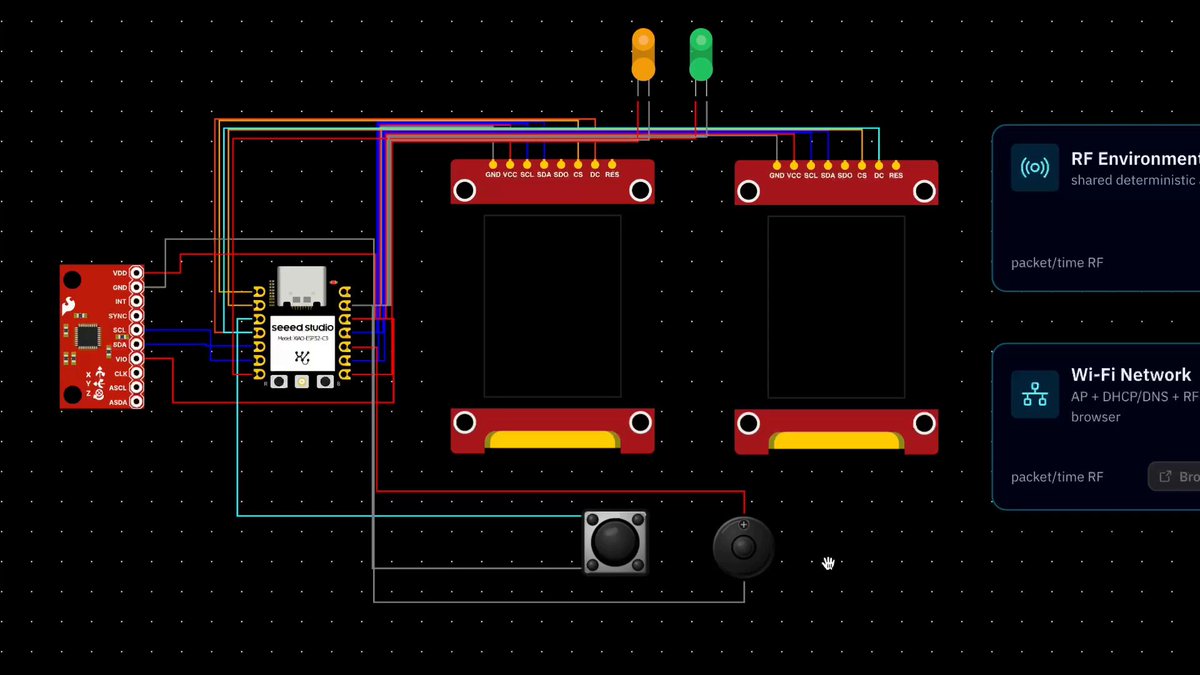
Playing Snake through Jev on simulated ESP32-C3 firmware using the OpenRouter API
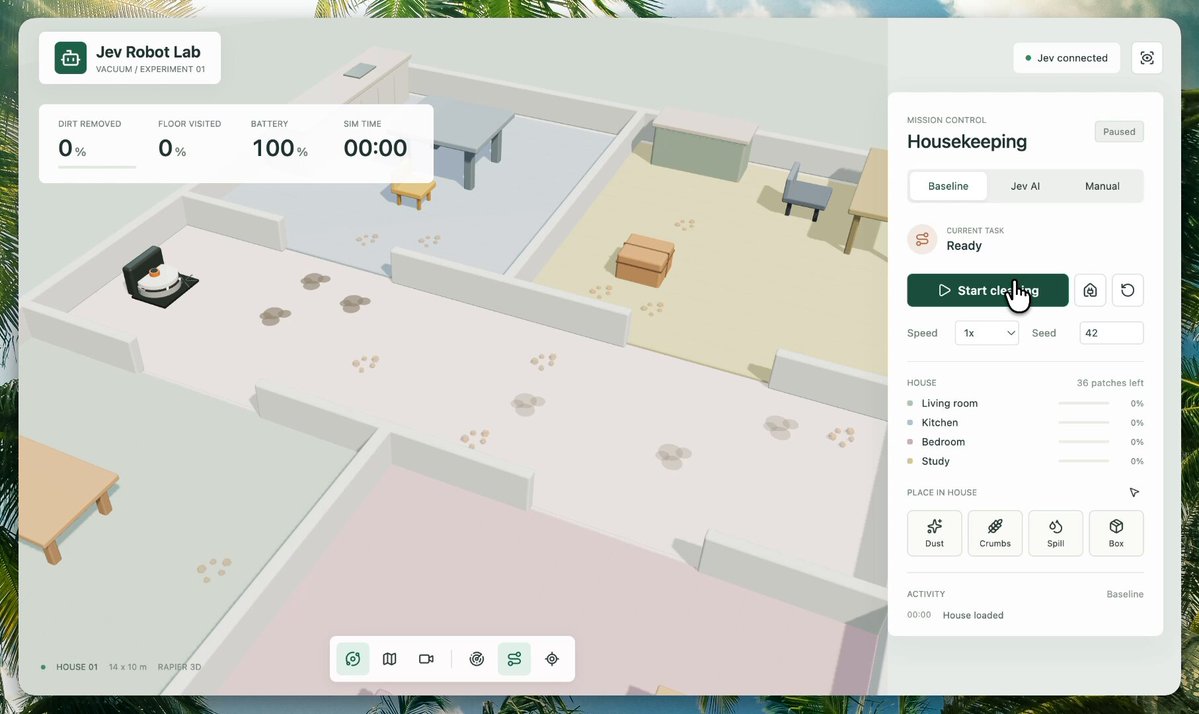
Controlling a robot-vacuum simulation from sensory state in a one-shot Astra-generated experiment
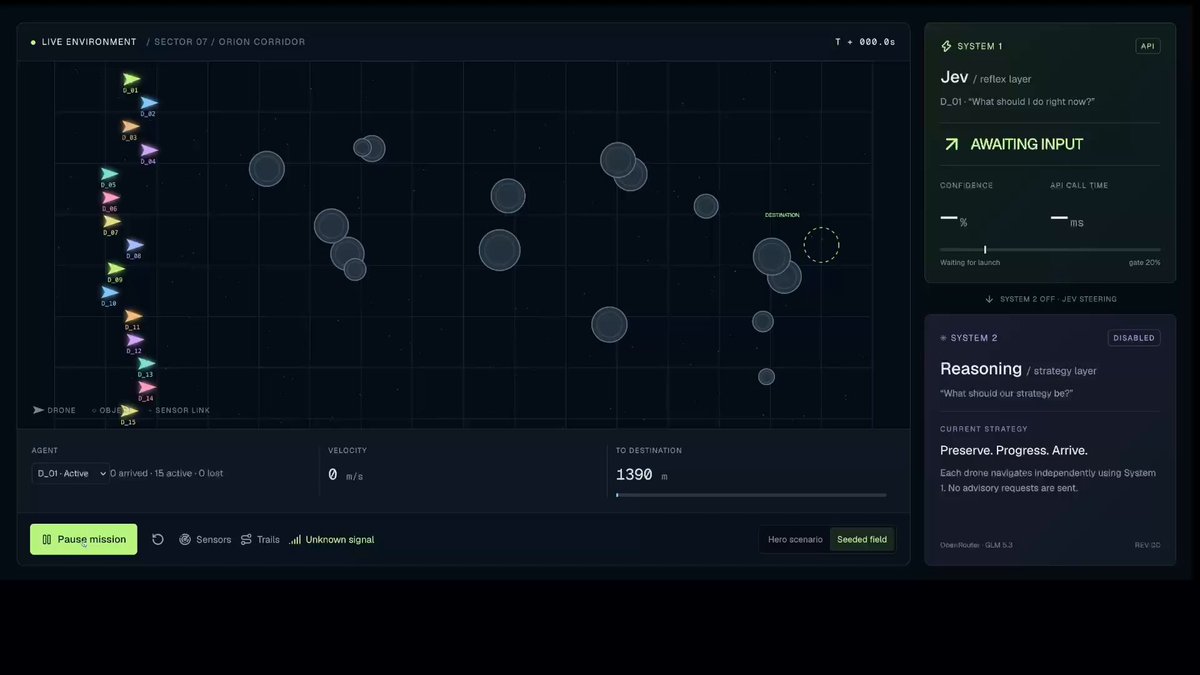
Navigating 15 autonomous drones through an asteroid field with reported latency below 300 ms and 100% survival
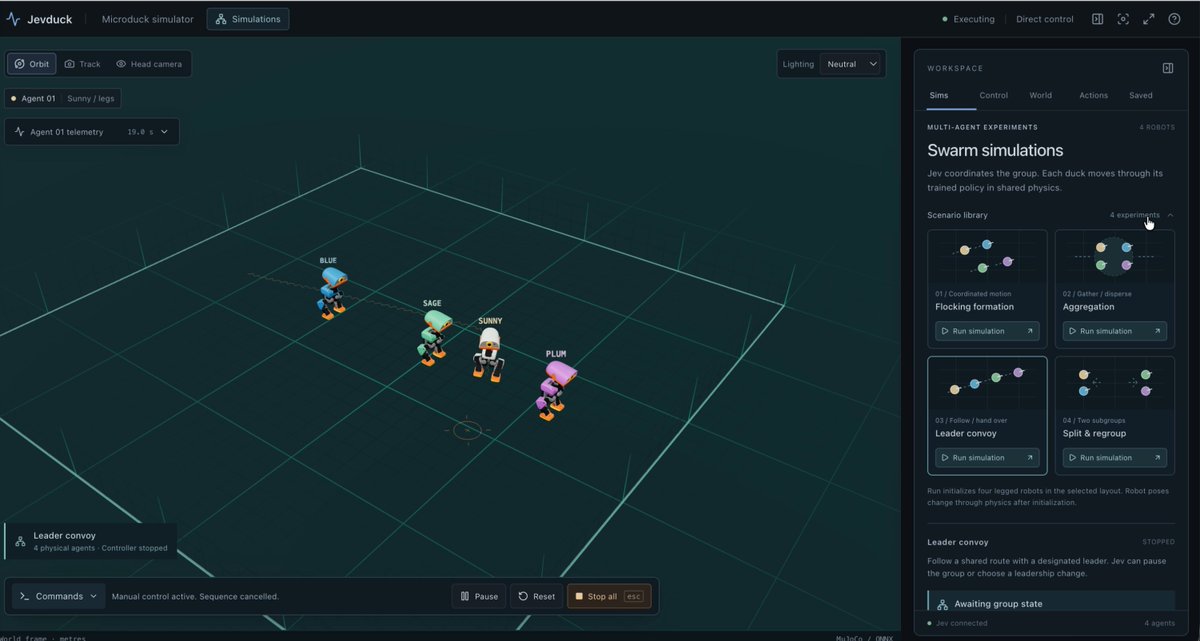
Connecting typed decisions to the Microduck simulator while MuJoCo computes dynamics and ONNX policies control joints
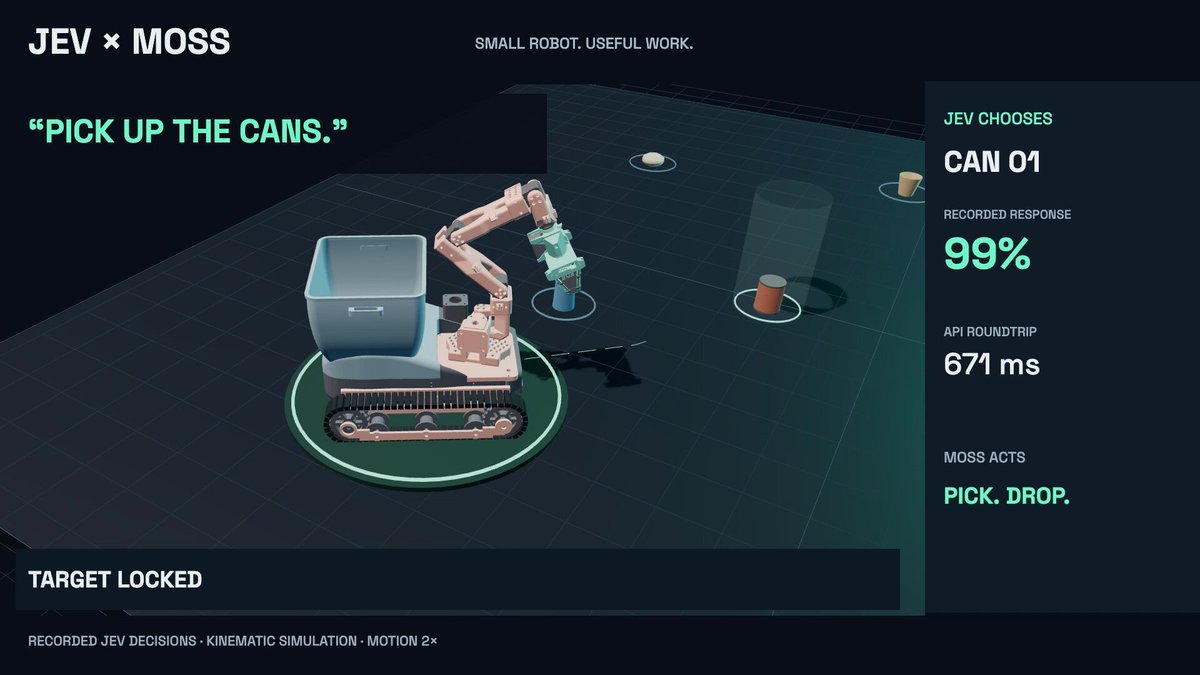
Selecting cans or bottles as litter targets so the MOSS robot can collect the requested objects in simulation
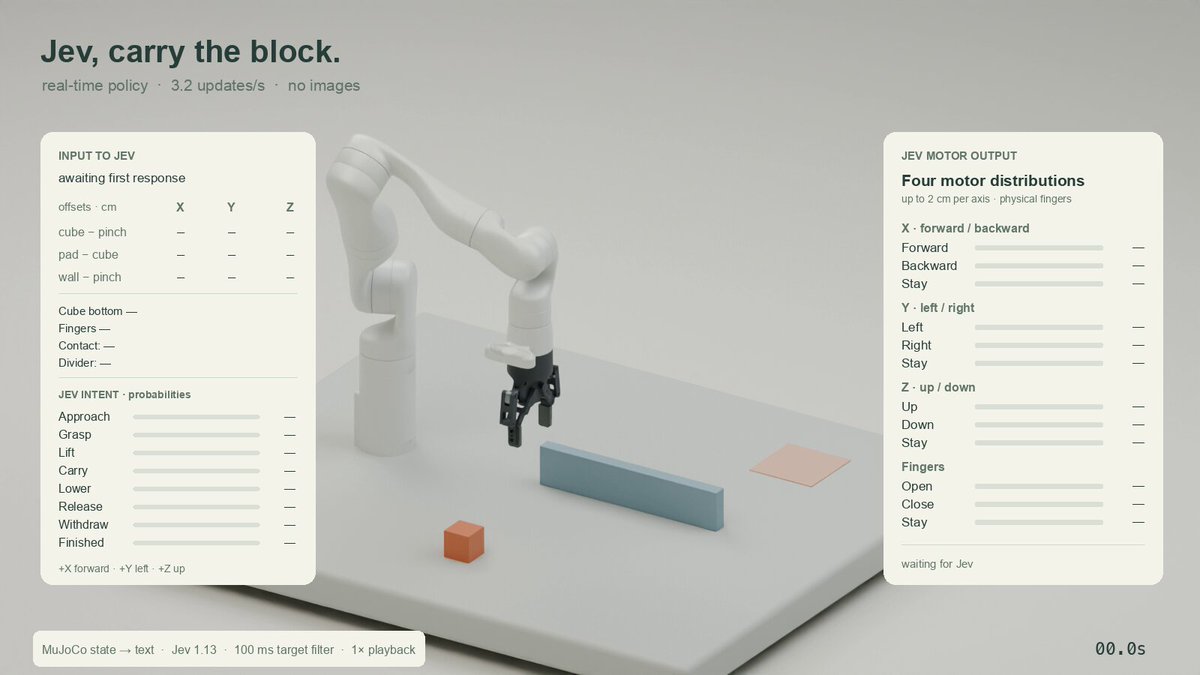
Controlling a MuJoCo robot from text geometry and contacts through separate task and arm-motion decisions
No matching demos
Try another keyword or return to the All category.